Robots rarely see the world as a whole. They piece it together from images, point clouds, and imperfect sensor measurements, yet must somehow make sense of it and decide what to do next. I’m interested in that space between perception and action, where geometry, understanding, and autonomy come together.
I’m Akash Kumbar, an M.S. by Research student and Graduate Student Researcher at the Robotics Research Center, IIIT Hyderabad, advised by Prof. Madhava Krishna.
My research explores how robots reconstruct, interpret, and navigate their surroundings, with work spanning 3D scene reconstruction, sensor calibration, and autonomous exploration. This work has found its way to ICCV and IROS, including a Best Paper Award at an IROS 2026 workshop. I also contribute to teaching and peer review, both of which give me opportunities to share what I know and engage with ideas beyond my own research.
Before IIIT Hyderabad, I studied Electronics and Communication Engineering at KLE Technological University, where I worked on point-cloud upsampling at the Center of Excellence in Visual Intelligence.
Outside research, I train in mixed martial arts, hold a black belt in karate, and run marathons.
Updates
- Sep 27, 2026 🏆 Our work Beyond Frontiers won the Best Paper Award at the Learning Across Navigation Fields workshop at IROS 2026!
- Sep 01, 2026 Serving as a reviewer for ICVGIP 2026.
- Jun 06, 2026 Our work Beyond-Frontiers: Scene-Anomaly Guided Autonomous Exploration has been accepted in IROS 2026.
- Jun 25, 2025 Our work Leveraging 2D Priors and SDF Guidance for Urban Scene Rendering 🚗 has been accepted in ICCV 2025 🎊
- Jul 30, 2024 I started my Master's (by Research) at RRC, IIIT Hyderabad under the guidance of Prof. Madhava Krishna.
- Aug 08, 2023 Our work ASUR3D: Arbitrary Scale Upsampling and Refinement of 3D Point Clouds has been accepted in ICCVW 2023.
- Aug 07, 2023 Our work TP-NoDe: Topology-Aware Progressive Noising and Denoising of Point Clouds Towards Upsampling has been accepted in ICCVW 2023.
Research
* indicates equal contribution
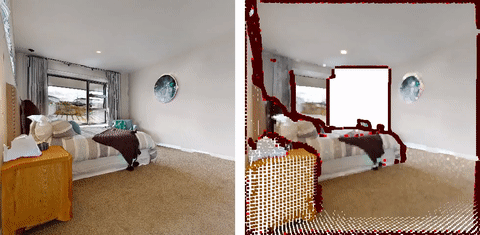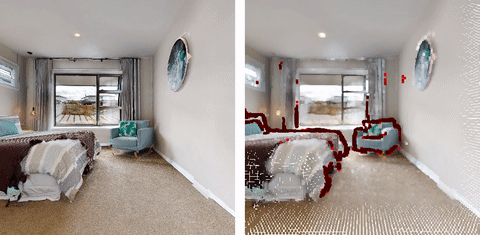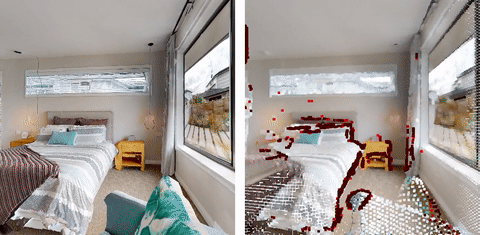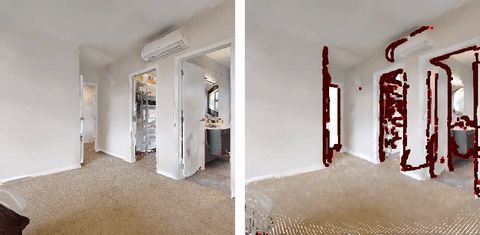 Beyond Frontiers: Scene-Anomaly Guided Autonomous Exploration
Akash Kumbar, Abhinav Raundhal, Madhava Krishna
Proceedings of the 2026 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2026)
🏆 Best Paper Award, Learning Across Navigation Fields Workshop, IROS 2026
Project Page •
ArXiv
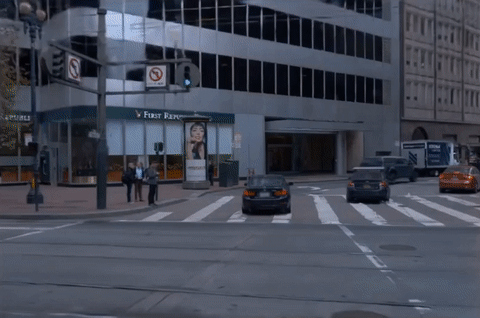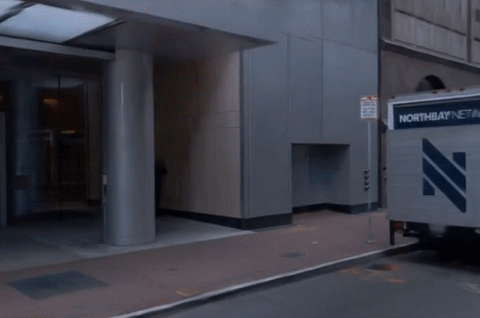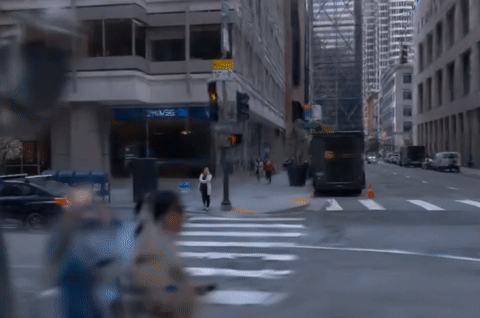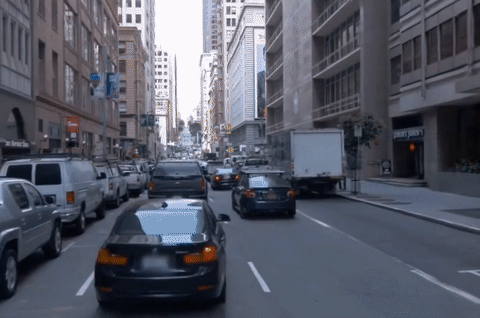 Leveraging 2D Priors and SDF Guidance for Dynamic Urban Scene Rendering
Siddharth Tourani, Jayaram Reddy, Akash Kumbar, Satyajit Tourani, Nishant Goyal, Madhava Krishna, N Dinesh Reddy, Muhammad Haris Khan
Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV), 2025
Project Page •
Proceedings •
ArXiv
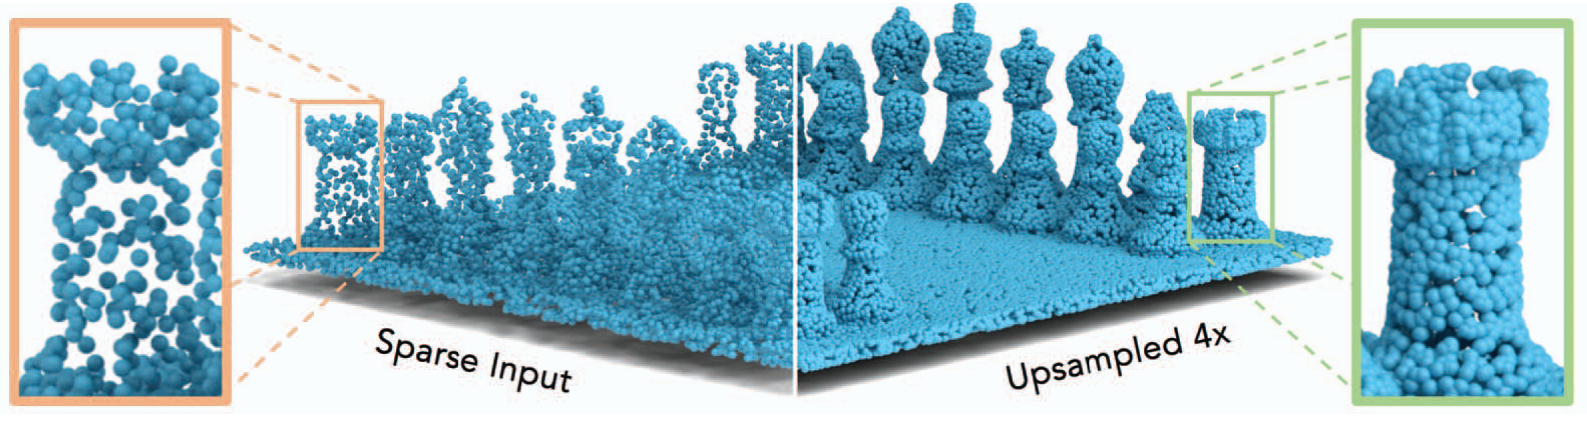 TP-NoDe: Topology-Aware Progressive Noising and Denoising of Point Clouds Towards Upsampling
Akash Kumbar*, Tejas Anvekar*, Tulasi Amitha Vikrama, Ramesh Ashok Tabib, Uma Mudenagudi
Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) Workshops, 2023
Proceedings
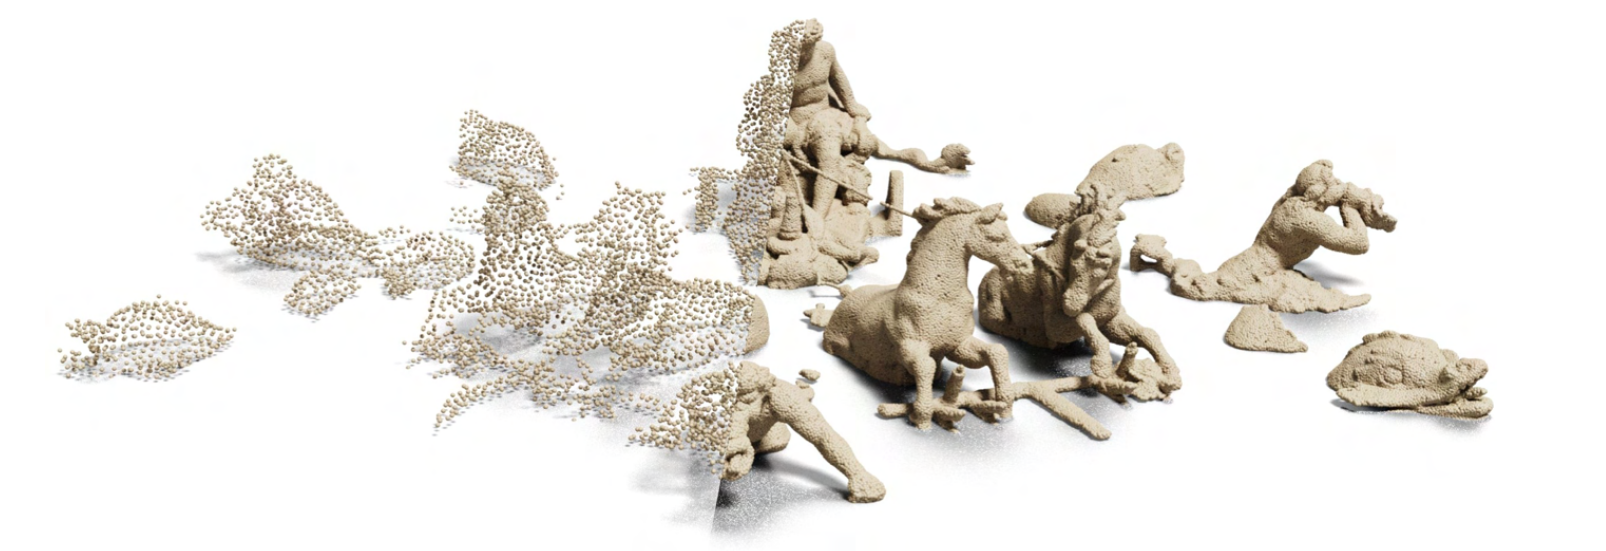 ASUR3D: Arbitrary Scale Upsampling and Refinement of 3D Point Clouds Using Local Occupancy Fields
Akash Kumbar, Tejas Anvekar, Ramesh Ashok Tabib, Uma Mudenagudi
Proceedings of the IEEE/CVF International Conference on Computer Vision (ICCV) Workshops, 2023
Proceedings
Awards & Achievements
Best Paper Award
Sep 2026Learning Across Navigation Fields: Challenges and Future Work, IROS 2026 Workshop
For Beyond Frontiers: Scene-Anomaly Guided Autonomous Exploration (project page)
Certificate of Appreciation
Bosch PRIXEL Program, Bosch Global Software Technologies
For developing a robust, real-time computer-vision model for speed-breaker and pothole detection (project page)
Teaching & Service
Teaching Assistant, Mobile Robotics, IIIT Hyderabad, Monsoon 2026
Mentoring students, supporting course instruction, designing projects and assignments, and grading coursework.
Instructor, RRC Summer School, IIIT Hyderabad, 2025 and 2026
Taught deep learning for 3D vision, neural representations, and explicit scene representations, including 3D Gaussian Splatting. 2026 lecture
Reviewer, ICVGIP 2026
Reviewing submissions for ICVGIP 2026.
Reviewer, SeMaNa: Semantic-Aware Mapping and Navigation, IROS 2026 Workshop
Reviewing submissions for the SeMaNa workshop at IROS 2026.
Projects
A selection of my work in computer vision, deep learning, and robotics.
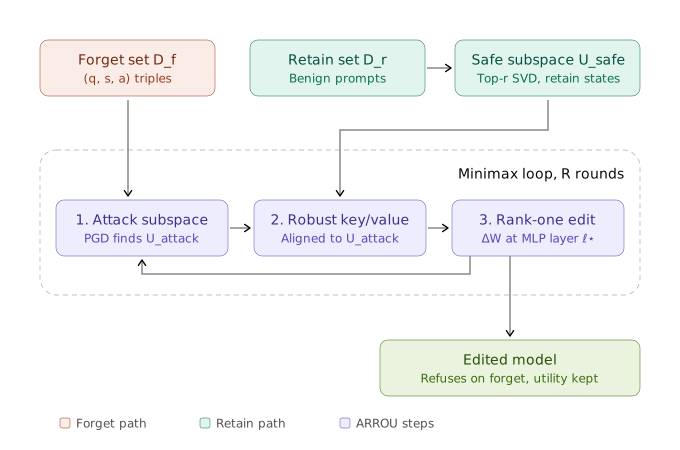 ARROU: Adversarially Robust Rank-One Unlearning
Targeted LLM unlearning through latent adversarial training and localized rank-one model editing
View project →
MAST3R-SLAM
Camera-pose extraction and 3D scene reconstruction from point clouds and images
View project →
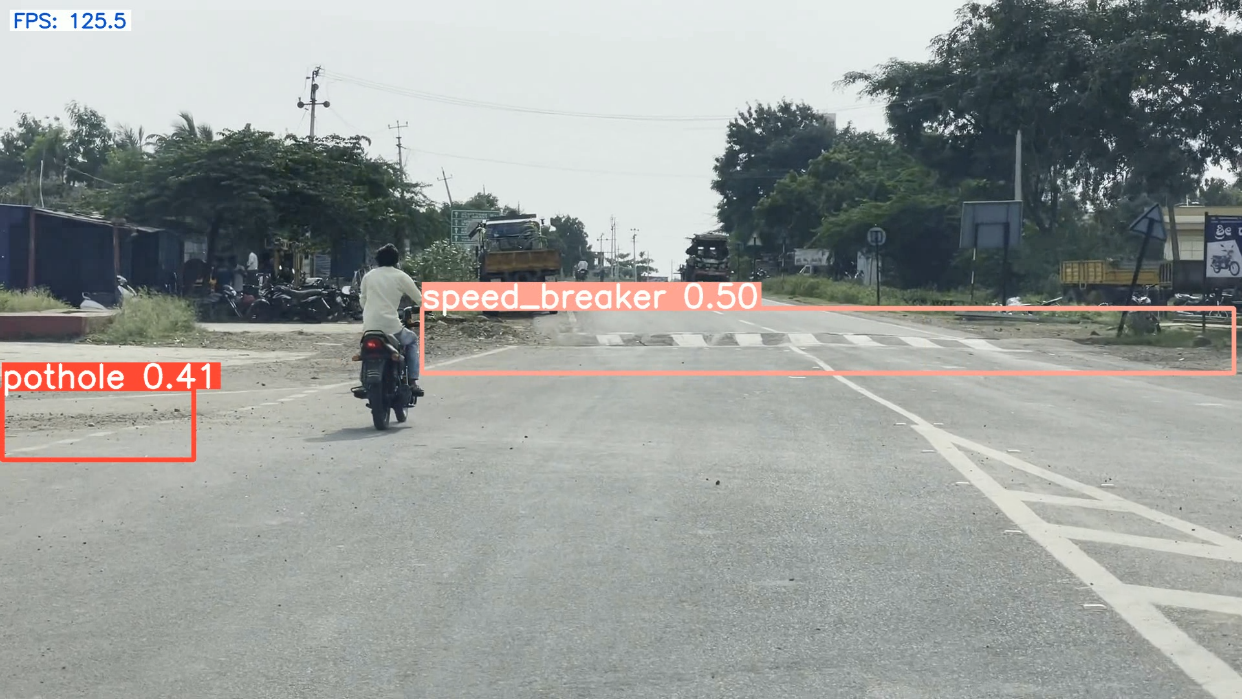 Camera-Based Vehicle Functions
Completed as a part of Bosch's PRIXEL program
View project →
Template borrowed from Cheng Chi's personal page